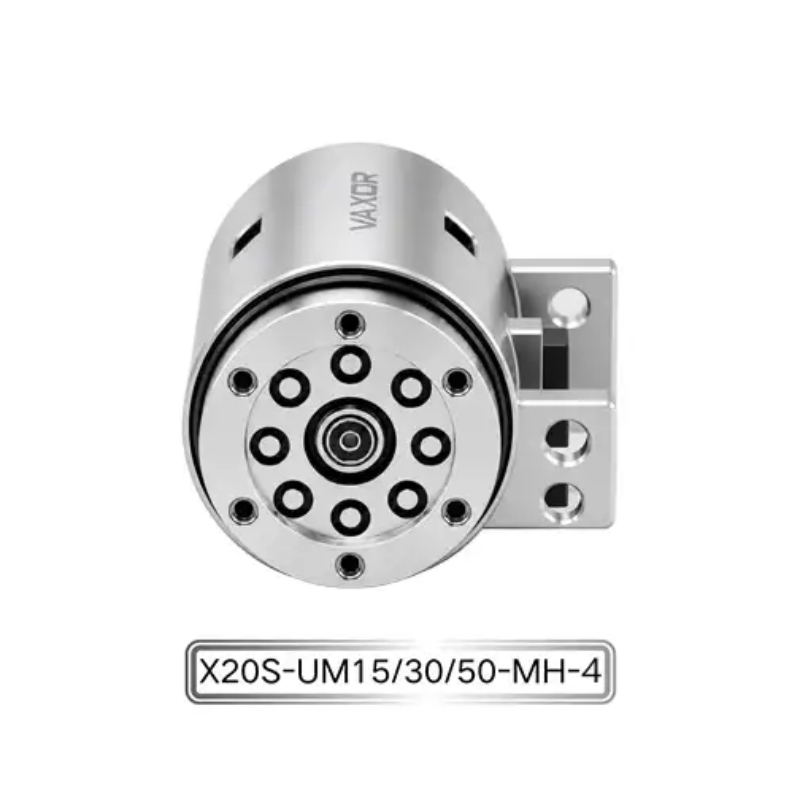
Φ20mm Micro Joint Actuator
Ultra-compact Φ20mm robotic joint actuator with high torque density and precise motion control.
Product Introduction
The Φ20mm Micro Joint Actuator is an ultra-compact motion module designed for robotic joints and precision motion applications where installation space, torque density, and control accuracy are critical. With an overall size of only Φ20mm × 20mm, the flagship X20 series integrates an axial-flux motor architecture with a miniature reduction mechanism to deliver high torque output within an extremely small footprint.
Compared with conventional motor designs, its innovative axial-flux architecture provides over 30% higher torque density, helping equipment manufacturers achieve more powerful joint performance without increasing actuator size. Supporting multiple voltage and gear ratio configurations, the actuator offers flexible integration options for different robotic structures and intelligent devices.
The X20 Φ20mm Micro Joint Actuator combines compact mechanical design, high torque density, absolute magnetic encoder feedback, and SPI communication. It is suitable for applications requiring precise positioning, responsive motion, and lightweight drive systems.
Key Product Features and Advantages
1. Ultra-Compact Φ20mm Design
With dimensions of just Φ20mm × 20mm, the X20 actuator is engineered for space-constrained applications. Its miniature structure makes it suitable for compact robotic joints, lightweight mechanisms, and precision equipment where conventional drive systems may be difficult to integrate.
2. High Torque Density Axial-Flux Motor
The innovative axial-flux motor architecture delivers over 30% higher torque density than conventional designs. This enables stronger output performance within a compact installation space, supporting the development of smaller and more capable robotic systems.
3. High Torque Output
The actuator provides continuous torque of up to 450 mNm and initial torque of up to 800 mNm. These output characteristics support robotic joint movements and precision mechanical operations requiring high torque relative to actuator size.
4. Multiple Gear Ratio Options
Available gear ratios include 15:1, 30:1, and 50:1, allowing equipment designers to select a suitable transmission configuration according to output torque and motion requirements.
5. Absolute Magnetic Encoder
Equipped with an absolute magnetic encoder, the actuator provides position feedback for motion control systems. This supports accurate positioning and integration into robotic joint control architectures.
6. SPI Communication Interface
The SPI communication interface supports data exchange with compatible control systems, facilitating integration into embedded motion control applications and intelligent robotic devices.
7. Multiple Voltage Options
The actuator supports 12V, 24V, and 48V configurations, offering flexibility for different power supply architectures and equipment designs.
8. Lightweight Construction
With a weight ranging from 37.2 g to 41.6 g, the X20 helps reduce the mass of moving components. Its lightweight design is particularly useful for compact robotic joints and applications where weight reduction contributes to overall system performance.
Product Specifications
| Parameter | Specification |
|---|---|
| Product Name | Φ20mm Micro Joint Actuator |
| Product Series | X20 |
| Model | X20S/L-UM15/30/50-MH-4 |
| Dimensions | Φ20mm × 20mm |
| Operating Voltage | 12V / 24V / 48V |
| Gear Ratio | 15 / 30 / 50 |
| Continuous Torque | Up to 450 mNm |
| Initial Torque | Up to 800 mNm |
| Encoder Type | Absolute Magnetic Encoder |
| Communication Interface | SPI |
| Weight | 37.2–41.6 g |
| Motor Architecture | Axial-Flux Motor |
Note: Maximum torque values and weight may vary depending on the selected configuration. Please confirm the corresponding model specifications before ordering.
Model and Configuration Options
The X20 series provides different configuration options to accommodate varying robotic joint requirements.
-
Voltage Selection: 12V, 24V, or 48V.
-
Gear Ratio Selection: 15:1, 30:1, or 50:1.
-
Model Configuration: X20S/L-UM15/30/50-MH-4.
-
Feedback System: Absolute magnetic encoder.
-
Communication: SPI interface.
When selecting a configuration, engineers should consider the required output torque, motion characteristics, power supply, mechanical installation space, and controller compatibility.
Typical Applications
The Φ20mm Micro Joint Actuator is designed for compact drive systems across robotics, precision equipment, and intelligent machinery.
Robotics and Robotic Joints
Suitable for compact robotic joint assemblies where limited installation space and high torque density are important. Its miniature dimensions support the development of lightweight robotic structures and integrated motion systems.
Humanoid Robotics
The combination of compact size, torque output, and position feedback makes the actuator a potential drive solution for miniature humanoid robot joints and other space-constrained robotic mechanisms.
Medical Devices
Can be considered for compact medical equipment and precision mechanisms requiring controlled movement and miniature drive components, subject to application-specific safety and performance validation.
Precision Instruments
Suitable for integration into precision instruments and automated mechanisms where compact dimensions and accurate motion control are required.
Intelligent Equipment
Supports the development of compact intelligent terminals, automated devices, and miniature electromechanical systems requiring integrated motion solutions.
Technical Integration and Selection Considerations
For successful integration, equipment designers should evaluate the actuator according to the complete mechanical and electrical system requirements.
-
Mechanical Compatibility: Confirm the Φ20mm × 20mm installation envelope and mounting interface.
-
Torque Requirements: Select an appropriate gear ratio based on the required continuous and peak torque.
-
Power Supply: Match the 12V, 24V, or 48V version to the system power architecture.
-
Position Feedback: Check compatibility between the absolute magnetic encoder and the host controller.
-
Communication Protocol: Ensure that the control system supports the SPI interface.
-
Operating Conditions: Evaluate temperature, duty cycle, mechanical loading, and other application-specific requirements.
Providing the intended application, installation drawings, and control requirements can help determine the most suitable configuration.
About VAXOR
VAXOR is a micro-drive technology company founded in 2024 and headquartered in Suzhou, China. The company focuses on developing micro joint actuators and ultra-micro coreless motors for robotics, medical devices, precision instruments, and intelligent equipment.
By combining axial-flux motor technology, PCB/FPCB winding, optimized electromagnetic design, and miniature reduction mechanisms, VAXOR develops compact motion solutions with high torque density, fast response, precise control, and high efficiency.
R&D and Engineering Capabilities
-
Interdisciplinary R&D Team: Expertise covering motor design, precision manufacturing, structural engineering, robotics control, and intelligent manufacturing.
-
Engineering Development: Capabilities extending from prototype validation and pilot production to batch delivery.
-
International Technical Background: Core team members with academic and industrial R&D experience from China and overseas.
-
Long-Term Technical Focus: Dedicated to high-performance micro motors and intelligent equipment.
-
Scalable Manufacturing Development: Focus on translating advanced motor technologies into practical and scalable production solutions.
VAXOR products have been supplied or sampled to robotics companies, technology enterprises, and research institutions worldwide.
The company's technology roadmap focuses on three core requirements of micro-drive systems: compact size, high performance, and scalable production. Its solutions are developed to support the growing demand for smaller, more powerful, and more intelligent motion systems.
Ordering Information
To help identify the appropriate micro joint actuator configuration, buyers and engineering teams are encouraged to provide the following information when making an inquiry:
-
Required actuator model or series
-
Operating voltage: 12V, 24V, or 48V
-
Preferred gear ratio: 15:1, 30:1, or 50:1
-
Required continuous and initial torque
-
Mechanical installation dimensions
-
Encoder and SPI communication requirements
-
Intended application and operating conditions
-
Estimated order quantity
Technical drawings and system integration requirements can also be provided for configuration evaluation.
Compact Motion Solutions for Next-Generation Robotics
For robotic developers and intelligent equipment manufacturers seeking high-performance miniature drive components, the X20 series offers an integrated approach to compact joint actuation. Its axial-flux motor architecture, high torque density, absolute magnetic encoder, and lightweight structure support the development of space-efficient motion systems.
With a dedicated focus on micro-drive technology and engineering implementation, VAXOR provides miniature actuator solutions for robotics, precision instruments, medical equipment, and intelligent devices.
Contact us to learn more about the Φ20mm Micro Joint Actuator, discuss technical specifications, and explore suitable micro-drive configurations for your application.
Related products
-
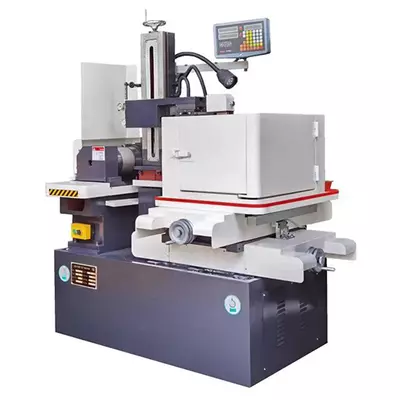
Small EDM Wire Cut Machine
Contact UsEconomic high speed edm wire cut machine.
Main Features:
Roller for X/Y axis, also called hard rail ( V rail);
With ±3° taper as standard, ±15°, ±30°, ±45° as option;
Accuracy: ±0.01/300mm;
Roughness: Ra 1.0-2.5 µm;
Low consumption, material saving. -
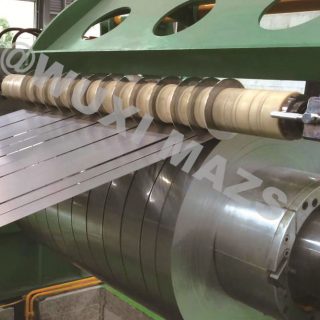
MA-(0.8~4MM)×1300MM Steel Coil Slitting Equipment
Contact UsMA-(0.8~4MM)×1300MM Steel Coil Slitting Equipment can process the slitting of the coil with different sizes to small strips for processing various kinds of metal coil materials.
-
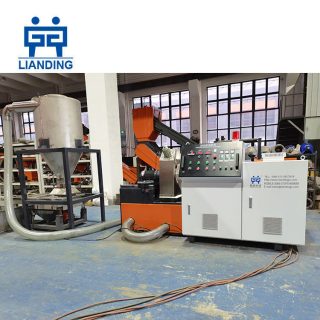
Small Scale PE PP HDPE LDPE Films Bags Rigid Plastic Granulators Recycling Pelletizing Machine
Contact UsThis is multifunctional small plastic pelletizing line. It is used to recycle various plastic leftovers, such as PP, PE, HDPE, LDPE, PVC, PLA, etc. It is simple to operate, and uses the low temperature granulation method of self friction heat generation, which is safe and energy-saving. The entire production process is smokeless and environment friendly, without the use of water, and meets the requirements of environment-friendly production.
-
Oxygen Rich Side Blown Melt Melting Furnace
Contact UsThe oxygen rich side blown molten pool melting furnace is an efficient and energy-saving steel melting equipment. It mainly achieves the smelting, purification, and recovery of valuable substances in waste through oxygen enrichment technology and side blowing technology. Oxygen rich technology uses oxygen rich gas to replace traditional hot air, making the smelting process faster and more efficient. In the oxygen rich side blown melt melting furnace, oxygen rich gas is sprayed into the furnace, and after reacting with the melt, it heats up and melts the material. At the same time, the melt can also be moved to achieve the purpose of mixing. Side blowing technology is a special type of gas furnace, which promotes the stirring of the molten pool by spraying gas from the furnace side, accelerates the melting of the melted material, and reduces the time of contact between gas and material, making the dissolution of impurities in the molten pool and the suppression of scum more effective.
Reviews
There are no reviews yet.